Field Report: Deployment of High-Speed MIG/MAG Welding Robot in Gainesville, Georgia
1. Project Scope and Environmental Context
This report details the technical deployment and optimization of a high-speed MIG/MAG Welding Robot at a Tier-1 automotive sub-assembly facility in Gainesville, Georgia. The primary objective was to transition a manual welding line for structural seat frames and instrument panel supports to a fully automated cell. The project focused on “High-Speed” throughput without sacrificing the structural integrity of thin metal sheet welding applications, which typically range from 1.2mm to 2.5mm in thickness.
Operating in the Georgia climate presents specific challenges for automated Arc Welding Solutions. During the commissioning phase in July, ambient humidity levels in the workshop frequently exceeded 75%. This necessitated immediate adjustments to our gas delivery systems and wire storage protocols to prevent hydrogen-induced porosity, a common failure point in high-volume production environments in the Southeastern United States. Our response was to implement inline gas dryers and climate-controlled wire payoff stations, ensuring the integrity of the MIG/MAG Welding Robot’s input materials.
2. Technical Integration of the MIG/MAG Welding Robot
The core of the installation is a 6-axis industrial robot integrated with a high-speed digital power source. Unlike legacy systems, the modern MIG/MAG Welding Robot functions as a unified node within the factory’s Industrial Internet of Things (IIoT) framework. The synergy between the robot’s motion controller and the power source’s waveform generator is what defines our modern Arc Welding Solutions.
2.1 Motion Control and Path Calibration
For high-speed execution, we utilized a “look-ahead” algorithm that allows the robot to maintain a constant surface speed of 85 cm/min on complex geometries. We found that at these speeds, traditional air-cooled torches were insufficient. We upgraded the system to a liquid-cooled 500A torch assembly. This change was vital to maintain the Tool Center Point (TCP) stability. In thin metal sheet welding, even a 0.5mm deviation in TCP due to thermal expansion can result in a “missed seam” or a “burn-through” event.
2.2 Waveform Optimization
The “High-Speed” aspect of this MIG/MAG Welding Robot is not just about arm movement; it is about the frequency of the short-circuit or pulse cycle. We implemented a Modified Short Circuit (MSC) process. By rapidly reducing the current at the moment of droplet detachment, we minimized spatter—a critical requirement for the GA facility to reduce post-weld grinding labor costs.
3. Implementing Advanced Arc Welding Solutions
The term “Arc Welding Solutions” refers to the holistic approach we took to bridge the gap between mechanical hardware and metallurgical requirements. In the Georgia workshop, we faced an inconsistent power grid in the industrial park, leading to voltage fluctuations that affected arc stability.
3.1 Voltage Compensation and Stability
To stabilize the MIG/MAG Welding Robot, we integrated an active voltage compensation module within the power source. This ensured that the arc length remained constant despite external power draws from neighboring CNC machines. This is a crucial component of our Arc Welding Solutions; without it, the high-speed pulse parameters would drift, causing inconsistent penetration in the thin metal sheet welding process.
3.2 Shielding Gas Dynamics
We moved away from a standard 75/25 Argon/CO2 mix to a specialized 90/10 blend. This change was driven by the need for a narrower plasma column. In thin metal sheet welding, a wide arc spreads heat too far into the base metal, increasing the Heat Affected Zone (HAZ) and causing warping. The 90/10 mix, combined with the robot’s precision, allowed for a “stiff” arc that focused energy exactly at the root of the joint.
4. Challenges in Thin Metal Sheet Welding
Welding sheets thinner than 2.0mm at high speeds is a exercise in heat management. The GA facility’s parts are stamped mild steel, often with slight variations in fit-up tolerance. This is where the MIG/MAG Welding Robot must be more than a “dumb” machine.
4.1 Gap Bridging and Burn-Through
During the first week of testing, we experienced a 12% reject rate due to burn-through on lap joints. The thin metal could not dissipate the heat fast enough at high travel speeds. The solution was two-fold:
1. We implemented a “Sync-Pulse” technology, which oscillates the wire feed speed in sync with the current. This creates a “cooling” phase within the weld puddle every few milliseconds.
2. We adjusted the torch angle from a 15-degree push to a 10-degree push to reduce the intensity of the arc force directly on the leading edge of the puddle.
4.2 Distortion Control
Thin sheets are notorious for “oil-canning” or buckling under thermal stress. To combat this, our Arc Welding Solutions included a revised clamping sequence. We programmed the MIG/MAG Welding Robot to perform “stitch” welds in a non-linear sequence—jumping across the part to balance the thermal input—before returning to complete the full seams. This reduced final part distortion by 40% compared to the manual baseline.
5. Synergy in the Workshop: Man and Machine
The integration of a MIG/MAG Welding Robot in a Georgia workshop often meets resistance from the veteran manual workforce. A key part of our field service was training the local operators to become “Robot Technicians” rather than just “Button Pushers.”
The synergy occurs when the operator understands that the Arc Welding Solutions we provide are tools to manage the physics of the arc. We taught the Gainesville team how to read the “arc signature” on the digital interface. By monitoring the wire feed motor’s current draw, operators can now predict when a contact tip is wearing out before it causes a failure in the thin metal sheet welding line. This proactive maintenance approach is what sustains high-speed production over three shifts.
6. Lessons Learned and Engineering Recommendations
After 60 days of operation, the Gainesville site has provided several “lessons from the dirt” that should be applied to future North American deployments:
6.1 Grounding is Non-Negotiable
We initially saw “arc blow” issues that were traced back to poor work-piece grounding. In high-speed thin metal sheet welding, the magnetic field generated by high-frequency pulses can deflect the arc. We recommended dual-grounding points on the fixture table, which eliminated the erratic arc behavior immediately. Never rely on the fixture hinges for a ground path.
6.2 Wire Quality Matters
We switched from a standard grade wire to a premium “high-glide” coated wire. While the per-pound cost increased, the reduction in liner friction allowed the MIG/MAG Welding Robot to maintain the precise wire-feed speeds required for the Sync-Pulse process. In Arc Welding Solutions, the cheapest consumable is often the most expensive bottleneck.
6.3 Software Version Control
We encountered a bug where the robot’s “Resume” function after an E-stop would cause a 200ms surge in current, blowing through the thin sheet. Working with the OEM, we patched the firmware to include a “Soft-Start” routine on all restarts. Engineers must ensure that the robot software and power source firmware are synced and validated for the specific thin metal sheet welding WPS (Welding Procedure Specification).
7. Conclusion
The Gainesville, GA deployment demonstrates that a MIG/MAG Welding Robot is only as effective as the Arc Welding Solutions surrounding it. By addressing the specific challenges of thin metal sheet welding through pulse-synchronization, environmental controls, and rigorous grounding, we have achieved a cycle time reduction of 35% while maintaining a 98% first-pass yield. The synergy between the high-speed motion of the robot and the intelligent response of the power source has set a new benchmark for the facility’s automated fabrication capabilities.
Report Compiled By:
Senior Welding Engineer, Field Operations
Georgia District Office
-


LT240S tube laser cutting machine
-
LT120S tube laser cutting machine
-
Sale

Tank Fillet Welding Machine
Original price was: $1,000.00.$900.00Current price is: $900.00. -
Sale

MAK100 tube laser cutting machine
Original price was: $5,500.00.$5,000.00Current price is: $5,000.00. -

portable plasma air cutting machine
$1,200.00 -

2in1 fiber laser cutting machine
-

Air cooling Laser welding machine
-

HF h beam laser cutting machine
-

LT240 laser cutting machine
-

Laser welding machine
-


Cobot Welding Station
-

Gantry welding robot solution
-

Tracked Wheeled AGV Welding robot
-

LFH6020 Fiber laser cutting machine
-
LFP6020
-

robotic welidng machine
Advanced Fiber Laser Tube Processing Technology
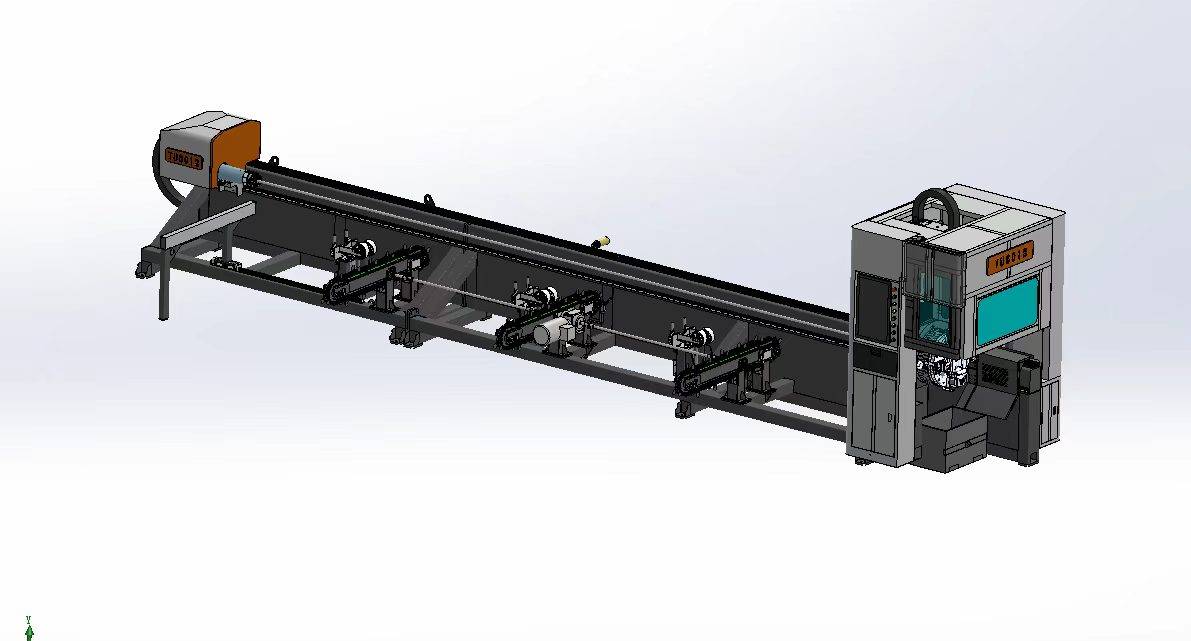
Our CNC Fiber Laser Tube Cutting systems revolutionize metal fabrication by integrating high-precision cutting, punching, and profiling into a single automated workflow. Designed for versatility, this technology handles a wide array of profiles including Round, Square, Rectangular, and Oval tubes, as well as complex L-shaped and U-shaped channels.
- Precision Punching: High-speed hole punching with micron-level accuracy, eliminating the need for mechanical drilling or die-stamping.
- Complex Profiling: Advanced 3D pathing allows for intricate interlocking joints and specialized notch cuts, ideal for structural frames.
- High Material Efficiency: Intelligent nesting software minimizes scrap, reducing raw material costs across large production runs.
- Clean Finish: Delivers oxide-free, burr-free edges that require zero secondary grinding before welding.

Seamlessly processing multiple profiles with consistent precision.
Global Delivery & Logistics



From our high-tech manufacturing facility directly to your global site. PCL WeldCut ensures secure packaging, professional handling, and reliable international logistics to safeguard your equipment throughout the entire journey.