Field Engineering Report: Deployment of 3000W Cobot Welding Machine in Barcelona FAB-LAB
1. Project Scope and Site Environment
This report details the technical commissioning and operational evaluation of a 3000W fiber laser Cobot Welding Machine at a high-precision fabrication facility in the Zona Franca industrial district of Barcelona, Spain. The facility specializes in architectural stainless steel and light-gauge automotive components. The primary objective was to replace manual TIG (Tungsten Inert Gas) stations with an automated solution capable of handling high-volume thin metal sheet welding while maintaining the aesthetic standards required by European design markets.
The site presented specific logistical constraints: limited floor space and a workforce transitioning from traditional artisan welding to digital manufacturing. Unlike traditional industrial robots, the integration of Collaborative Robotics allowed us to bypass the need for extensive safety fencing, fitting the machine directly into the existing workflow alongside manual finishing stations.
2. Technical Synergy: The Cobot Welding Machine and Collaborative Robotics
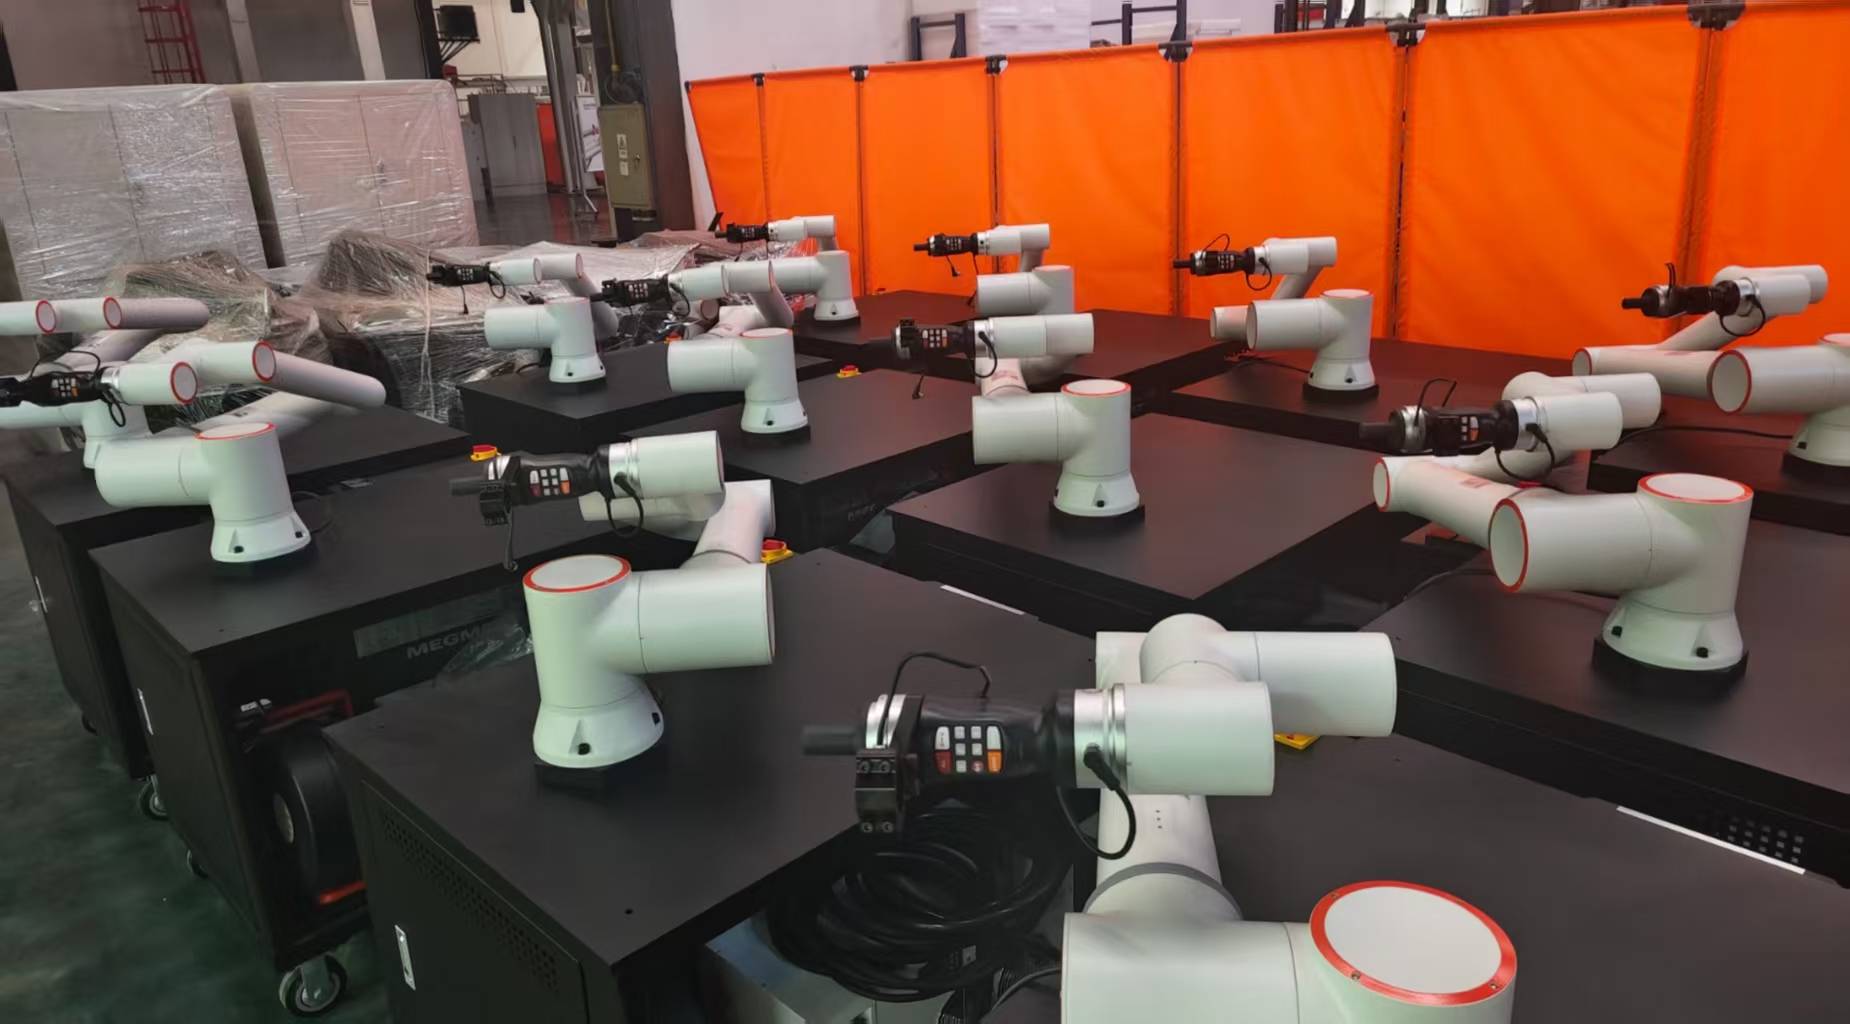
In this deployment, the synergy between the Cobot Welding Machine hardware and the principles of collaborative robotics was the deciding factor for operational success. Traditional automation requires a “hard” perimeter—physical cages and light curtains that isolate the process. In the Barcelona workshop, space is at a premium (valued at over €15/sqm in industrial zones). By utilizing a collaborative framework, we integrated the 3000W laser source onto a six-axis arm equipped with torque sensors and area scanners.
Integrated Safety and Programming
The “collaborative” aspect refers to the safety-rated monitored stop (SRMS) and hand-guiding capabilities. During the first week of testing, we leveraged the lead-through programming feature. Instead of writing complex lines of G-code, the local welding lead—a veteran with 20 years of manual experience—manually guided the 3000W torch head along the seam. The software captured these waypoints, allowing for rapid iteration of weld paths. This bridge between human expertise and robotic precision is the core strength of collaborative robotics in a high-mix, low-volume (HMLV) environment.
3. Process Analysis: Thin Metal Sheet Welding (0.8mm to 2.0mm)
The technical core of the Barcelona project was thin metal sheet welding, specifically SS304 and SS316L alloys. Manual TIG welding on 1.0mm sheets often results in significant thermal distortion (warping) due to the high heat input required to maintain a stable arc. The 3000W laser source, integrated into the cobot, operates with a much higher power density, allowing for significantly faster travel speeds and a reduced Heat Affected Zone (HAZ).
Power Modulation and Wobble Parameters
To prevent burn-through on 0.8mm sheets, we implemented a “wobble” function—a high-frequency oscillation of the laser beam within the weld pool.
- Wobble Frequency: 150 Hz to 200 Hz
- Wobble Width: 1.5mm to 2.0mm
- Power Profile: Ramped at start/end to avoid cratering.
By distributing the 3000W of energy across a slightly wider path, the Cobot Welding Machine achieved full penetration while keeping the sheet temperature low enough to touch within seconds of the pass. This is critical for the “thin metal” sector where post-weld straightening usually accounts for 30% of total labor costs. In the Barcelona shop, we reduced post-weld rework by 85%.
4. Comparison: Manual vs. Cobot Deployment
During a 48-hour head-to-head trial on a standard architectural bracket (1.2mm brushed stainless), the following data was logged:
Manual TIG (Standard)
- Travel Speed: 120mm/min
- Post-Weld Grinding: Required (4 minutes per unit)
- Reject Rate (Distortion): 4.2%
3000W Cobot Welding Machine
- Travel Speed: 650mm/min
- Post-Weld Grinding: Not required (autogenous weld finish)
- Reject Rate (Distortion): <0.5%
The collaborative robotics approach allowed the operator to load one side of the dual-zone table while the cobot welded the other. This “interweaving” of human and robotic tasks effectively doubled the throughput without increasing the facility footprint.
5. Engineering Challenges and Field Solutions
Deployment in an old Barcelona warehouse presented unique challenges, particularly regarding atmospheric conditions and power stability.
Gas Shielding and Turbulence
We initially faced porosity issues in the weld bead. Investigation revealed that the shop’s ventilation system created cross-drafts that disrupted the Argon shield at the laser nozzle. Because thin metal sheet welding is highly sensitive to oxidation, we had to design custom “trailing shield” nozzles and install localized windbreaks. The lesson learned: even with a high-end Cobot Welding Machine, basic welding physics—specifically shielding gas coverage—remains the most common point of failure.
Jigging and Fixturing Precision
The most significant hurdle was the “Precision Gap.” Manual welders compensate for poor fit-up in real-time by slowing down or adding filler wire. A cobot, while collaborative, is only as good as the fit-up. We found that the standard thin metal sheet welding preparation used for TIG (with gaps up to 0.5mm) was unacceptable for the 3000W laser. We had to implement 3D-printed modular jigs to ensure a consistent gap of <0.1mm. Without this mechanical precision, the speed of the Cobot Welding Machine is negated by the time spent fixing “blow-throughs.”
6. Lessons Learned from the Barcelona Site
After three weeks of operational data, several “ground truths” emerged for senior engineers considering similar deployments:
The 3000W Power Ceiling
While 3000W is marketed as a high-penetration tool, its true value in thin metal sheet welding is the overhead it provides for high-speed “wobble” welding. We rarely operated at 100% duty cycle at full power; instead, we utilized the 3000W capacity to maintain stability at ultra-high speeds on 2.0mm plates, ensuring the laser source never labored near its thermal limit.
Human-Robot Interaction (HRI)
The term collaborative robotics is often misunderstood as “safe to be hit by.” In a welding context, it really means “safe to be near.” The integration of a Class 4 laser means safety is still paramount. We utilized a “hybrid” cell design in Barcelona—using laser-safe curtains that allowed the operator to stay within 1 meter of the machine to monitor the weld pool through a viewing window, rather than being stuck behind a remote console.
The Skills Shift
The most successful operators were not those with the best computer skills, but those with the best “eye” for the weld pool. We trained the manual welders to adjust the cobot’s “offset” and “laser focal point” based on the color of the plasma plume. This tactile feedback is essential for maintaining quality in thin metal sheet welding where material batches (especially from different suppliers in the EU) may vary slightly in their reflective properties.
7. Final Technical Recommendations
For future installations of the Cobot Welding Machine in similar European urban manufacturing hubs, I recommend the following:
- Prioritize Fixturing: Budget at least 20% of the project cost for high-precision pneumatic or modular clamping. Laser welding is a “fit-up intensive” process.
- Atmospheric Control: Ensure the welding zone is protected from ambient drafts. Thin metal sheet welding with fiber lasers is highly susceptible to “nitriding” if the shield gas is compromised.
- Synergistic Training: Lean into the collaborative robotics aspect by involving manual welders early. Their ability to troubleshoot the “look” of a weld is faster than any sensor currently on the market.
- Power Supply: In older industrial sectors like parts of Barcelona, ensure a dedicated, stabilized power line. The 3000W source is sensitive to voltage drops which can cause “micro-stuttering” in the laser pulse, leading to inconsistent penetration.
In conclusion, the Barcelona deployment proves that a Cobot Welding Machine is not merely a replacement for human labor, but a tool for precision enhancement. By managing the thermal input on thin metal sheet welding through the precision of collaborative robotics, we achieved a level of finish that was previously impossible at these production speeds.
-


LT240S tube laser cutting machine
-
LT120S tube laser cutting machine
-
Sale

Tank Fillet Welding Machine
Original price was: $1,000.00.$900.00Current price is: $900.00. -
Sale

MAK100 tube laser cutting machine
Original price was: $5,500.00.$5,000.00Current price is: $5,000.00. -

portable plasma air cutting machine
$1,200.00 -

2in1 fiber laser cutting machine
-

Air cooling Laser welding machine
-

HF h beam laser cutting machine
-

LT240 laser cutting machine
-

Laser welding machine
-


Cobot Welding Station
-

Gantry welding robot solution
-

Tracked Wheeled AGV Welding robot
-

LFH6020 Fiber laser cutting machine
-
LFP6020
-

robotic welidng machine
Advanced Fiber Laser Tube Processing Technology
Our CNC Fiber Laser Tube Cutting systems revolutionize metal fabrication by integrating high-precision cutting, punching, and profiling into a single automated workflow. Designed for versatility, this technology handles a wide array of profiles including Round, Square, Rectangular, and Oval tubes, as well as complex L-shaped and U-shaped channels.
- Precision Punching: High-speed hole punching with micron-level accuracy, eliminating the need for mechanical drilling or die-stamping.
- Complex Profiling: Advanced 3D pathing allows for intricate interlocking joints and specialized notch cuts, ideal for structural frames.
- High Material Efficiency: Intelligent nesting software minimizes scrap, reducing raw material costs across large production runs.
- Clean Finish: Delivers oxide-free, burr-free edges that require zero secondary grinding before welding.

Seamlessly processing multiple profiles with consistent precision.
Global Delivery & Logistics



From our high-tech manufacturing facility directly to your global site. PCL WeldCut ensures secure packaging, professional handling, and reliable international logistics to safeguard your equipment throughout the entire journey.