Field Engineering Report: Implementation of 1000W Robotic Arm Welder in Turin Heavy Fabrication Sector
1.0 Introduction and Site Context
The following report outlines the technical deployment and calibration of a 1000W Robotic Arm Welder at a Tier-1 heavy machinery facility in Turin, Italy. Turin remains the industrial heartbeat of Italian automotive and structural engineering, providing a unique environment where legacy metalworking expertise meets aggressive Industrial Automation. The primary objective of this commissioning was to transition from manual multi-pass GMAW (Gas Metal Arc Welding) to an automated cell designed specifically for Thick Plate Steel welding, focusing on 15mm to 25mm structural brackets.
The transition to a Robotic Arm Welder in this specific geographic context is driven by the need for localized precision and the rising cost of skilled manual labor. The site required a system capable of 24/7 operation with minimal thermal distortion, a feat notoriously difficult when dealing with high-gauge carbon steel.
2.0 System Architecture: The Robotic Arm Welder
The core of the installation is a 6-axis industrial manipulator integrated with a 1000W fiber-delivered welding head. While 1000W is often considered the entry point for laser-based Industrial Automation, its application here serves a specialized purpose: high-density root pass penetration followed by synchronized wire-feed filling.
2.1 Kinematics and Reach
The Robotic Arm Welder features a 2.1-meter reach radius, essential for traversing the large-format plates used in Turin’s heavy equipment manufacturing. We utilized a floor-mounted track system to extend the linear workspace, allowing the robot to service two separate welding stations. This maximizes the duty cycle; while the robot welds in Station A, the operator loads Thick Plate Steel welding assemblies in Station B.
2.2 End-Effector Precision
The welding head is equipped with a coaxial laser tracking sensor. In the context of Thick Plate Steel welding, material inconsistencies—such as slight deviations in V-groove preparation—can lead to catastrophic weld failure. The sensor provides real-time feedback to the robot’s controller, adjusting the tool center point (TCP) at a frequency of 100Hz to compensate for fit-up gaps.
3.0 The Role of Industrial Automation in Turin’s Workshop
In Turin, Industrial Automation is not merely about replacing a welder’s hand; it is about data-driven consistency. The integration involves a centralized PLC (Programmable Logic Controller) that bridges the Robotic Arm Welder with the factory’s MES (Manufacturing Execution System).
3.1 Synchronized Positioners
To achieve high-quality welds on Thick Plate Steel welding projects, gravity must be leveraged. We integrated two-axis head-and-tailstock positioners into the automation loop. This allows the Robotic Arm Welder to maintain a “downhand” (1G/1F) position throughout complex circular paths. The synchronization ensures that as the positioner rotates the 250kg workpiece, the robot adjusts its travel speed and torch angle in a 1:1 ratio.
3.2 Adaptive Power Control
The 1000W power source is managed through an EtherCAT interface, allowing the automation system to vary the power output based on the thickness detected by the sensors. During the start and end of a seam—areas prone to crater cracks in thick sections—the Industrial Automation software executes a programmed ramp-down of power and a localized increase in shielding gas flow (90% Argon, 10% CO2).
4.0 Technical Challenges: Thick Plate Steel welding
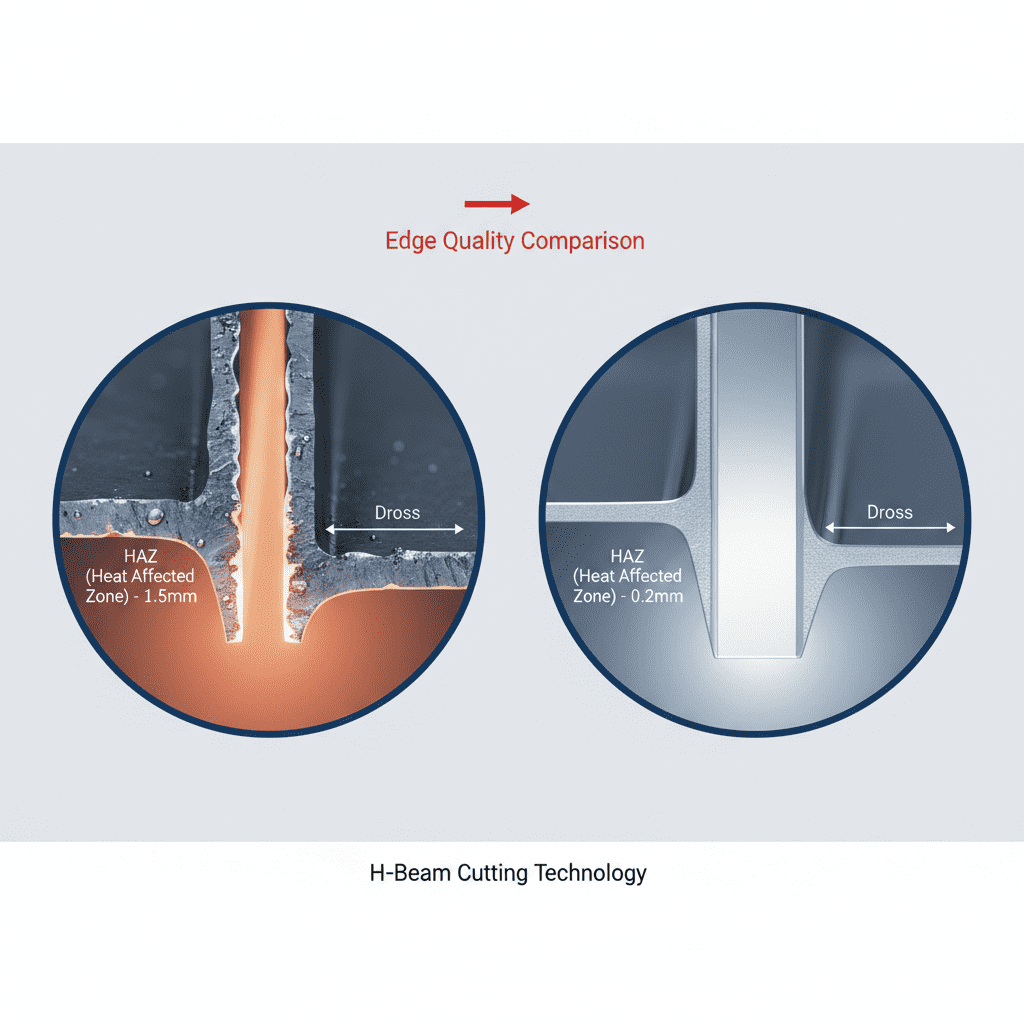
Welding thick-gauge material (S355JR grade steel common in Italy) presents thermal management hurdles that thin-sheet automation does not encounter. The primary challenge at the Turin site was the Heat Affected Zone (HAZ) and the requirement for deep penetration without excessive spatter.
4.1 Multi-Pass Strategy
For 20mm plates, a single pass is insufficient. We developed a three-pass logic:
- Root Pass: High-intensity 1000W concentrated beam to ensure full penetration at the base of the V-groove.
- Fill Pass: Oscillating (weave) pattern controlled by the Robotic Arm Welder to build volume while managing the molten pool.
- Cap Pass: Lower heat input, wider weave to ensure aesthetic consistency and structural integrity.
4.2 Managing Thermal Mass
Thick Plate Steel welding acts as a massive heat sink. In the Turin workshop, ambient temperatures vary significantly between winter and summer. We implemented an infrared pre-heating station as part of the Industrial Automation sequence. The robot will not strike an arc until the induction heaters have brought the plate to a minimum interpass temperature of 150°C, preventing hydrogen-induced cracking.
5.0 Engineering Lessons Learned from the Turin Deployment
Fieldwork often reveals discrepancies between theoretical CAD models and workshop reality. The following points summarize the “hard-won” data from this installation.
5.1 Cable Management is a Failure Point
During the first week of 24/7 Industrial Automation, we experienced intermittent signal loss. The culprit was the dress pack (the bundle of cables and hoses) snagging during high-angle maneuvers of the Robotic Arm Welder.
Lesson: Always over-spec the torsion ratings of the umbilical cables and use spring-loaded retractors. In a high-duty cycle environment like Turin, mechanical wear is your biggest enemy.
5.2 Shielding Gas Turbulence
When performing Thick Plate Steel welding at high travel speeds, the standard gas nozzle was creating a venturi effect, pulling in atmospheric oxygen and causing porosity.
Lesson: We switched to a high-flow diffuser nozzle and increased the pre-flow timer to 1.5 seconds. The Industrial Automation script was updated to include a “gas check” routine every 50 cycles to ensure the nozzle remained clear of spatter.
5.3 The “Human-Robot” Synergy
Initially, the local operators were skeptical of the 1000W system’s ability to handle heavy structural loads.
Lesson: Trust was built by demonstrating the “Repeatability Metric.” While a manual welder’s performance dips after the 6th hour of a shift, the Robotic Arm Welder maintained a variance of less than 0.1mm in weld throat thickness over a 12-hour period. We integrated a tablet-based HMI (Human Machine Interface) that allows the senior welders to “tweak” the wire feed speed on the fly, keeping them in control of the process while the robot handles the physical strain.
6.0 Productivity Gains and ROI
The implementation of Industrial Automation at this facility has resulted in a 40% reduction in cycle time per bracket. More importantly, the scrap rate—previously at 7% due to manual inconsistencies in Thick Plate Steel welding—has dropped to less than 0.5%.
The Robotic Arm Welder has also allowed the firm to bid on projects requiring ISO 3834-2 certification, as the automation system provides a digital “birth certificate” for every weld, logging voltage, current, gas flow, and travel speed for every millimeter of the seam.
7.0 Final Recommendations
Moving forward, the Turin site should consider upgrading the laser source to 2000W if they intend to move into 40mm+ thicknesses, as the 1000W unit is currently operating at 85% capacity during root passes. Additionally, the integration of an AI-based vision system for post-weld inspection would further streamline the Industrial Automation workflow, removing the need for manual ultrasonic testing on every part.
The synergy between the Robotic Arm Welder and the existing workforce confirms that the future of Italian manufacturing lies in high-tech augmentation rather than total replacement. The precision of the arm, combined with the metallurgical intuition of the Turin engineers, sets a new benchmark for Thick Plate Steel welding in the region.
Report Prepared By: Senior Welding Engineer
Location: Turin, Italy
Status: System Fully Operational
-


Cantilever Welding Robot solution
-


GF laser cutting machine
-

P3015 plasma cutting machine
-

LFP3015 Fiber Laser Cutter
-

pipe plasma cutting machine
-
LFH 4020 Fiber Laser Cutting Machine
-
LFP4020
-

gantry plasma air cutting machine
-

3D robot cutting machine
-

8 axis plasma cutting machine
-

5 axis plasma cutting machine
-

LT360 tube laser cutting machine
-

robot welding workstation
-

SF6060 fiber laser cutting machine
Advanced Fiber Laser Tube Processing Technology
Our CNC Fiber Laser Tube Cutting systems revolutionize metal fabrication by integrating high-precision cutting, punching, and profiling into a single automated workflow. Designed for versatility, this technology handles a wide array of profiles including Round, Square, Rectangular, and Oval tubes, as well as complex L-shaped and U-shaped channels.
- Precision Punching: High-speed hole punching with micron-level accuracy, eliminating the need for mechanical drilling or die-stamping.
- Complex Profiling: Advanced 3D pathing allows for intricate interlocking joints and specialized notch cuts, ideal for structural frames.
- High Material Efficiency: Intelligent nesting software minimizes scrap, reducing raw material costs across large production runs.
- Clean Finish: Delivers oxide-free, burr-free edges that require zero secondary grinding before welding.

Seamlessly processing multiple profiles with consistent precision.
Global Delivery & Logistics



From our high-tech manufacturing facility directly to your global site. PCL WeldCut ensures secure packaging, professional handling, and reliable international logistics to safeguard your equipment throughout the entire journey.
One thought on “Engineering Review: 1000W Robotic Arm Welder – Turin, Italy”
Excellent cut quality on 15mm alloy. The edges are clean and burr-free.