Automatic Girth Seam Welder with 3D Vision positioning for Pressure Vessels

In this article
Technical Integration of 3D Vision in Girth Seam Welding
In the fabrication of pressure vessels, the circumferential or girth seam represents a critical structural juncture that must withstand high internal pressures and thermal cycling. Conventional manual welding often suffers from inconsistencies due to operator fatigue and the physical constraints of rotating large-diameter cylinders. The implementation of robotic girth welding systems equipped with 3D Vision positioning addresses these variables by providing real-time geometric analysis of the weld joint.
The 3D vision system functions by projecting a structured light pattern or utilizing stereo-triangulation to map the groove profile. Unlike standard 2D sensors, 3D positioning identifies variations in root gap, bevel angle, and axial misalignment (hi-lo) before the arc is struck. This data is fed back to the robotic controller, which adjusts the torch trajectory and welding parameters—such as wire feed speed and travel speed—dynamically. For industrial engineers, this precision ensures that the MAG welding process maintains a constant fill volume regardless of upstream fit-up tolerances.
Optimization of the MAG Welding Process for Pressure Vessels
Metal Active Gas (MAG) welding is the preferred modality for pressure vessel girth seams due to its high deposition rates and ability to achieve deep weld penetration. When integrated with a robotic arm, the process can be tuned for multi-pass sequences that are essential for heavy-wall vessels. The robot maintains a consistent contact-tip-to-work distance (CTWD), which is vital for stabilizing the arc voltage and preventing spatter.
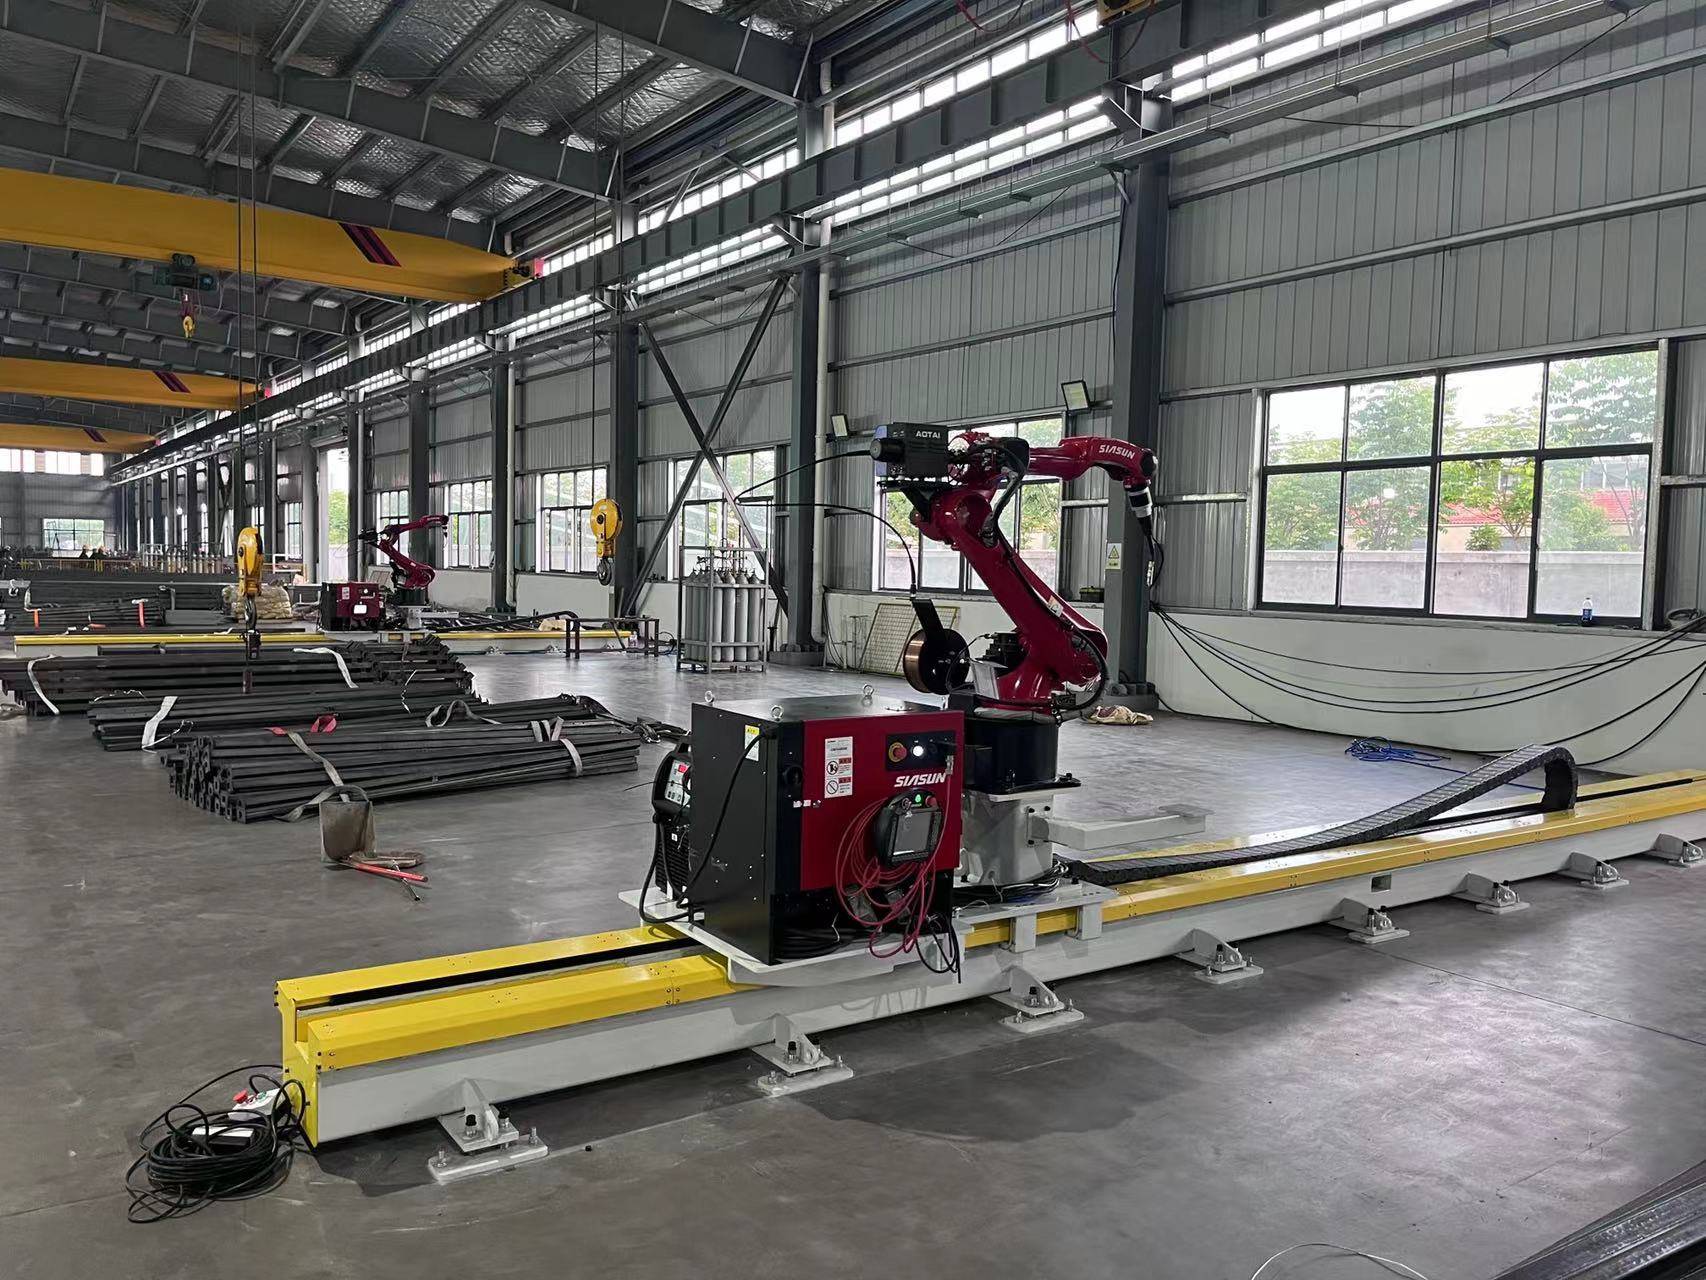
High-performance robotic cells utilize pulsed MAG technology to control heat input precisely. This is critical for maintaining the mechanical properties of the base metal and the Heat Affected Zone (HAZ). By automating the torch oscillation and travel speed, the system ensures that the bead profile meets stringent ASME or ISO standards without the risk of undercut or lack of fusion. The synchronization between the vessel rotator (turning rolls) and the robotic arm allows for continuous welding, significantly reducing the number of starts and stops where defects are most likely to occur.
Predictive Maintenance and System Reliability
Maintaining a Robotic Welding cell requires a shift from reactive to predictive maintenance strategies. The industrial engineer must focus on the consumables and the mechanical integrity of the robotic manipulator. The welding torch, specifically the contact tip and gas nozzle, are the most frequent points of failure. Automated torch cleaning stations, which include wire clipping and anti-spatter injection, are essential for maintaining a high cycle time efficiency.
Periodic calibration of the 3D vision sensor is necessary to ensure the coordinate system of the camera remains aligned with the robot’s tool center point (TCP). Mechanical wear on the vessel rotators can also introduce backlash or eccentricity, which the vision system can compensate for only to a certain threshold. Therefore, preventative maintenance schedules should include checking the gearbox lubrication of the rotators and the integrity of the grounding system to prevent electromagnetic interference (EMI) from disrupting the vision sensor’s data feed.
Calculating Labor ROI and Throughput Gains
The primary driver for adopting 3D vision positioning in welding is the measurable increase in labor ROI. In a manual welding environment, a high-quality girth seam on a large vessel might require two or three highly skilled welders working in shifts. These welders are subject to ergonomic strain and environmental hazards, leading to high turnover and recruitment costs. A robotic system, once programmed, can operate across multiple shifts with a single technician overseeing the operation.
To calculate the labor ROI, management must evaluate the reduction in man-hours per vessel. For example, if a manual weld requires 40 man-hours and the robotic system reduces this to 8 hours of supervised operation, the direct labor savings are substantial. Furthermore, the reduction in scrap and rework is a significant secondary gain. In manual processes, the repair of a failed radiographic test (RT) on a girth seam is exponentially more expensive than the initial weld. The consistency of robotic MAG welding minimizes these “hidden” costs.
Improving Workplace Safety and Environmental Impact
Beyond the financial metrics, the transition to automated systems enhances the safety profile of the shop floor. Girth welding often involves working in proximity to preheated vessels, which emit significant radiant heat. Automating the process allows the human operator to remain at a safe distance from the arc and the fumes generated during the MAG welding process. Modern robotic cells are frequently enclosed in flash-protection zones with integrated fume extraction systems that are more effective than localized manual extraction units.
Environmental efficiency is also improved through reduced consumable waste. Robotic systems use continuous wire drums rather than individual spools, reducing packaging waste and downtime for wire changes. The precision of the 3D vision system ensures that only the required amount of filler metal is deposited, preventing over-welding, which unnecessarily increases gas and wire consumption while adding excessive weight and stress to the pressure vessel structure.
Future-Proofing Fabrication through Data Acquisition
Integrating 3D vision provides a byproduct that is increasingly valuable in the era of Industry 4.0: data. Every girth seam welded by the robot generates a digital twin of the process. The system records the exact parameters used for every millimeter of the weld. This data logging is invaluable for quality assurance and traceability in industries like oil and gas or nuclear power, where documentation is as important as the physical weld itself.
Industrial engineers can analyze this data to identify bottlenecks or recurring fit-up issues in the preceding fabrication stages. For instance, if the 3D vision system consistently detects an over-sized gap in the 12 o’clock position, it indicates a systemic issue with the vessel fit-up station or the shell rolling process. This feedback loop allows for continuous improvement across the entire production line, far exceeding the localized benefits of a faster weld.
Conclusion of Engineering Strategy
The implementation of an Automatic Girth Seam Welder with 3D vision is not merely a purchase of hardware; it is a strategic upgrade to the manufacturing methodology. By focusing on the robotic girth welding capabilities and the high-deposition MAG process, manufacturers can decouple their production capacity from the volatile skilled labor market. The result is a more predictable, higher-quality, and more profitable pressure vessel production line that meets the rigorous demands of modern industrial standards.






