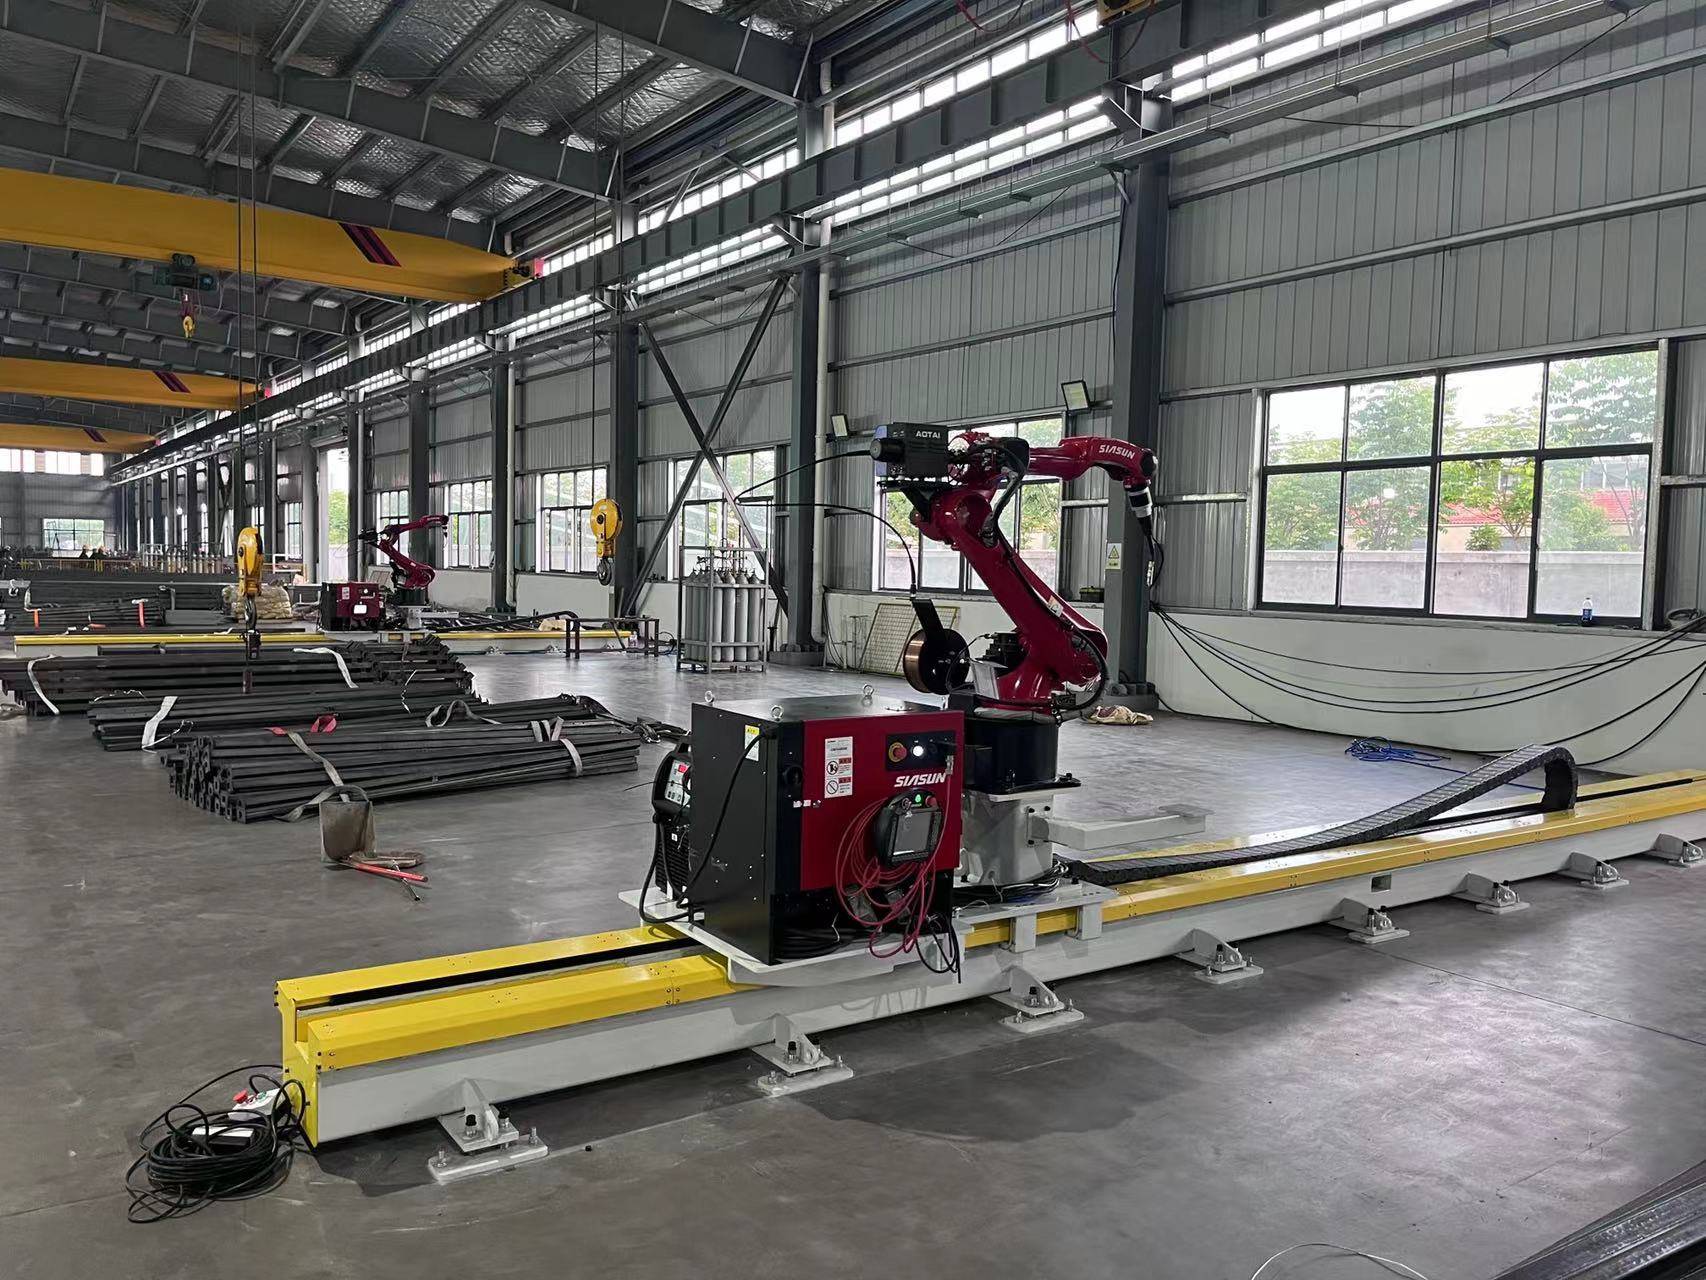
Automatic Girth Seam Welder with Magnetic Crawler for Shipbuilding

In this article
- Evolution of Girth Seam Welding in Naval Architecture
- The MAG Process in Automated Environments
- Maintenance Protocols for Robotic Crawler Systems
- Economic Impact and Labor ROI
- Arc-On Time Analysis
- Standardization and Workforce Upskilling
- Operational Constraints and Environmental Factors
- Geometry and Access Challenges
Evolution of Girth Seam Welding in Naval Architecture
In the structural assembly of large-scale vessels, the girth seam represents one of the most labor-intensive and quality-critical joints. Traditionally, these horizontal and vertical seams required highly skilled manual welders to operate in restrictive environments, often leading to inconsistent bead profiles and physical fatigue. The introduction of magnetic crawler technology has redefined the workflow by providing a stable, mechanized platform that traverses the hull plates without the need for fixed rails.
This transition is not merely a hardware upgrade but a fundamental shift in industrial engineering methodology. By automating the travel speed and torch oscillation, the shipyard can standardize the heat input, which is critical for maintaining the metallurgical integrity of high-tensile marine steels. The magnetic crawler uses high-flux permanent magnets or electromagnets to adhere to the curved surfaces of the hull, ensuring that the welding head remains at a constant standoff distance, regardless of the orientation.
The MAG Process in Automated Environments
The Metal Active Gas (MAG) process is the preferred choice for automated girth welding due to its versatility and high deposition rates. Unlike manual shielded metal arc welding (SMAW), MAG provides a continuous electrode feed, which is essential for the long runs required in shipbuilding. The robotic crawler facilitates a stable arc by eliminating the tremors associated with manual handling.
Optimizing Deposition Rates and Travel Speed
Efficiency in shipbuilding is measured by the mass of weld metal deposited per hour. Manual welding often peaks at 1.5 to 2.0 kg/h in vertical positions. In contrast, MAG welding efficiency when paired with an automated crawler can reach 4.0 to 6.0 kg/h. This is achieved through higher current densities and optimized wire feed speeds. The industrial engineer must balance the travel speed with the wire feed rate to ensure proper penetration while avoiding cold laps or undercut.
Shielding Gas Dynamics and Arc Stability
The choice of gas mixture, typically an Argon/CO2 blend, is optimized for the specific thickness of the hull plating. In automated crawler applications, gas flow must be strictly controlled to prevent porosity, especially when working in outdoor shipyard environments where wind can disrupt the shielding envelope. Automated systems often include integrated wind shields to protect the molten pool.
Maintenance Protocols for Robotic Crawler Systems
To maintain a high Mean Time Between Failure (MTBF), a rigorous preventive maintenance schedule is mandatory. Unlike manual torches, a magnetic crawler is a complex electromechanical system operating in a harsh environment filled with metallic dust and high-frequency interference.
Mechanical Drive and Magnet Integrity
The drive wheels or tracks of the crawler are subject to significant wear. Constant contact with abrasive steel surfaces requires weekly inspections for tread degradation. Furthermore, the magnetic modules must be cleared of slag and metallic debris daily. If debris builds up between the magnet and the hull, the “pull-off” force decreases, risking a catastrophic fall of the unit. Engineers must specify a safety factor for magnetic adhesion, usually 4:1, to account for surface irregularities and paint thickness.
Electrical System and Wire Feed Calibration
The umbilical cable, which carries power, gas, and wire, is a common failure point. Routine continuity tests and insulation checks are required to prevent signal loss between the controller and the crawler. The wire feed motor within the crawler must be calibrated monthly to ensure that the commanded wire speed matches the actual output. Variations as small as 5% can lead to unacceptable weld defects in 100% X-ray quality seams.
Economic Impact and Labor ROI
The primary driver for adopting ROI on automated welding systems is the dramatic reduction in man-hours per meter of weld. In a standard VLCC (Very Large Crude Carrier) or container ship, there are kilometers of girth seams. The financial justification for the crawler system is built on three pillars: duty cycle, rework reduction, and labor reallocation.
Arc-On Time Analysis
Industrial engineering studies consistently show that manual welders have an “arc-on” time of approximately 25% to 30%. The remainder of the shift is spent on slag removal, repositioning, and fatigue recovery. An Automatic Girth Seam Welder operates with an arc-on time of 70% to 80%. This three-fold increase in productivity allows a single operator to oversee two or even three crawlers simultaneously, effectively multiplying the output per head count.
Cost of Quality and Rework Minimization
In shipbuilding, the cost of repairing a failed weld is often ten times the cost of the initial weld. Manual welding in the vertical-up (3G) position is prone to slag inclusions and lack of fusion. The precision of the robotic crawler ensures a uniform bead with consistent penetration. By reducing the scrap and rework rate from a typical 5-8% in manual operations to less than 1% with automation, the shipyard saves significantly on ultrasonic testing (UT) and radiographic testing (RT) costs, as well as the labor required for grinding and re-welding.
Standardization and Workforce Upskilling
Implementing robotic girth welders allows the shipyard to utilize a less specialized labor pool for the actual welding task, while upskilling the existing workforce to become “Robotic Technicians.” This mitigates the global shortage of certified high-pressure welders. The standardization of the welding process also simplifies the Quality Assurance (QA) documentation, as the crawler can log parameters such as voltage, current, and travel speed in real-time, providing a digital twin of the welding operation for compliance and audit purposes.
Operational Constraints and Environmental Factors
While the benefits are clear, the industrial engineer must account for the specific constraints of the magnetic crawler. Surface preparation is paramount; while the crawler can traverse light rust, heavy scale or thick primer can impede both the magnetic grip and the electrical ground.
Geometry and Access Challenges
The crawler requires a specific clearance envelope. In tight sections of the bow or stern where the hull curvature is extreme, the crawler’s wheelbase must be adjustable to maintain contact. Modern units feature articulated frames to handle radii as small as 2 meters. Engineers must map the hull to identify zones where the crawler can operate autonomously and zones where manual intervention is still required, typically at the intersections of longitudinal and transverse bulkheads.
Integration with Shipyard ERP Systems
The final step in optimizing the use of automatic girth welders is integrating their performance data into the shipyard’s Enterprise Resource Planning (ERP) system. By tracking the meters welded per shift per machine, management can accurately predict delivery timelines and manage consumables inventory. This data-driven approach transforms the welding shop from a high-variance craft operation into a predictable, high-throughput industrial process.